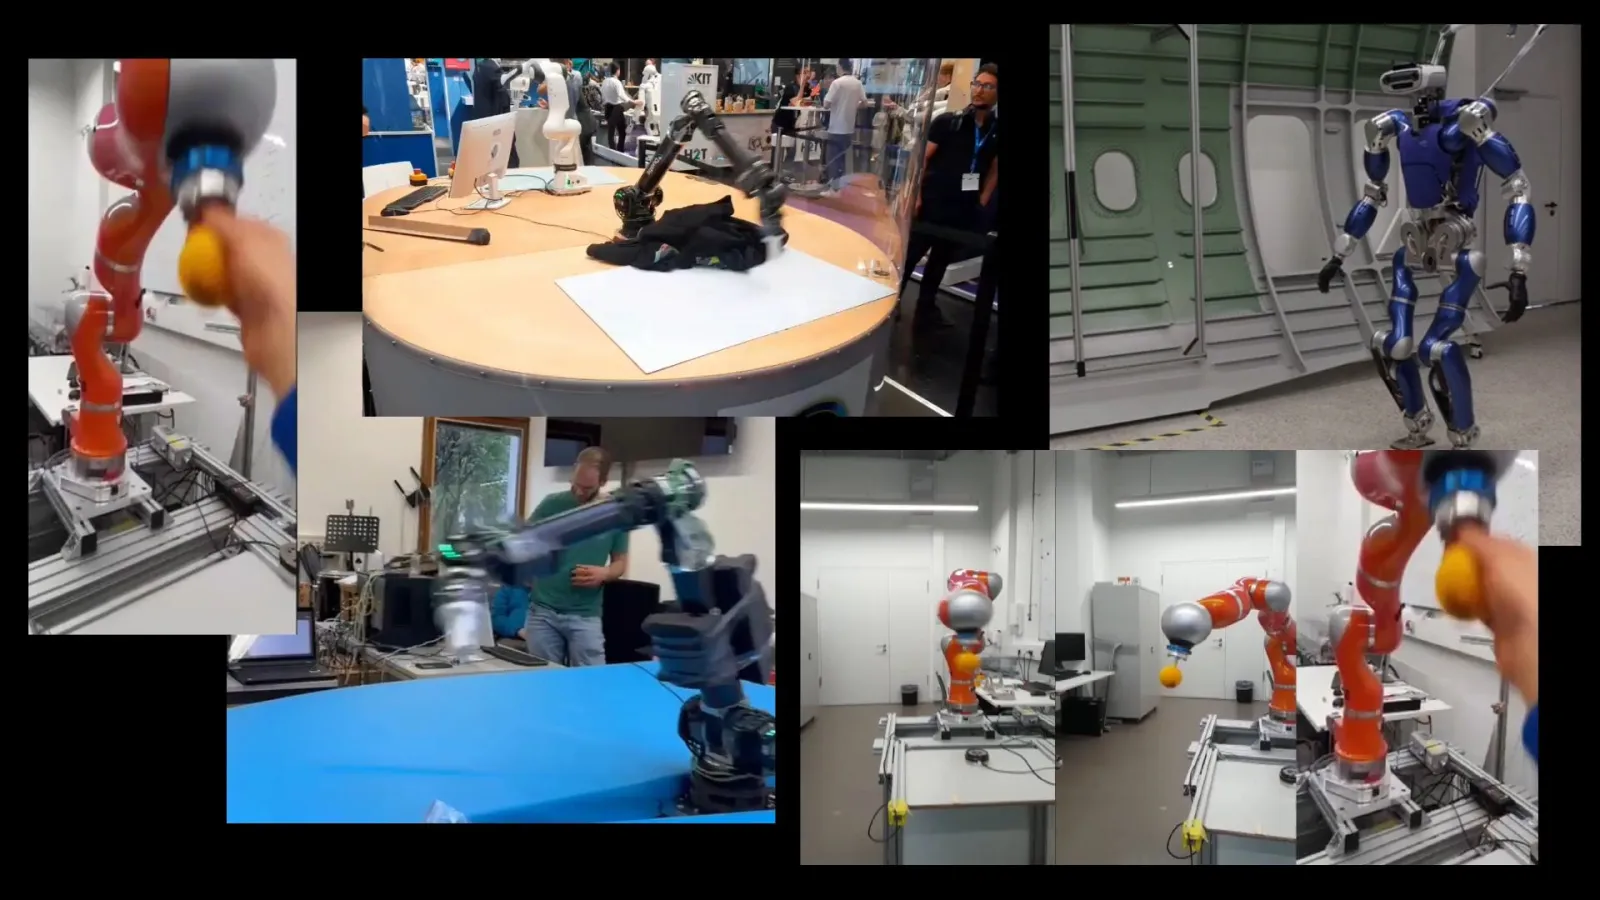
Contact-rich Manipulation
Master the moment when the robot touches the world.
Many of robotics’ hardest tasks begin where free-space motion ends. Assembly, insertion, fitting, pushing, pulling and manipulating constrained objects require robots to feel and respond to contact, rather than simply follow a predefined trajectory.
GECO SafeCore combines precise motion with compliant and force-based interaction, allowing robots to remain effective even when objects, fixtures and environments are not exactly where the model expected them to be.
Assembly · Insertion · Fitting · Tool use · Contact-rich manipulation